Boxi: Design Decisions in the Context of Algorithmic Performance for Robotics
Abstract summary
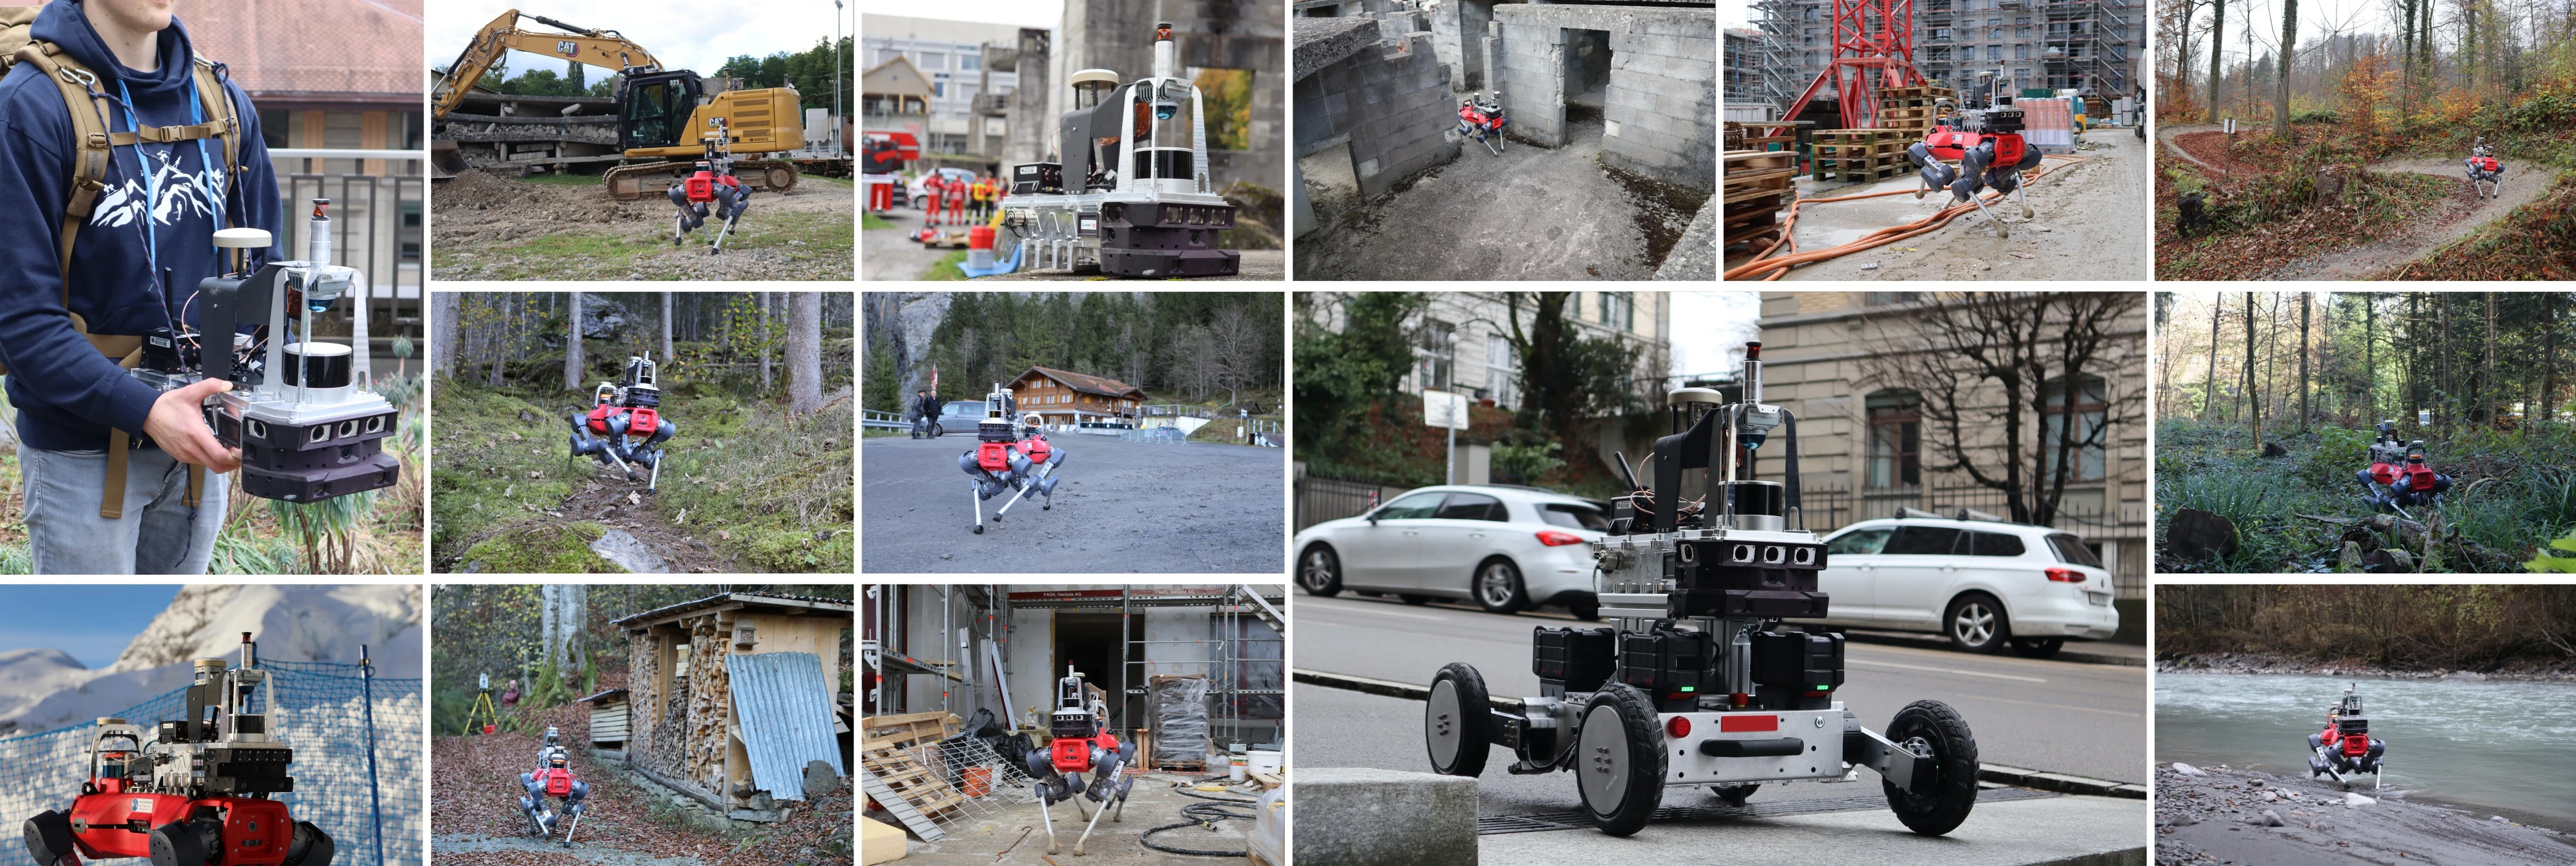
Boxi examines sensor-payload design as part of the robotics estimation problem. The system combines LiDAR, cameras with different imaging characteristics, inertial sensors and dual-antenna RTK-GNSS in one integrated package. The paper explains how sensor placement, computing, networking, power, thermal limits, synchronization and calibration influence the information available to downstream algorithms. Experiments assess the effect of these choices on state estimation and mapping in varied environments, including their cost implications. Alongside the hardware and software, the work provides a practical set of design lessons for building mobile sensing systems. Deployments across different applications demonstrate how the same payload can support field robotics beyond a single experimental setup.