Autonomous Forest Inventory with Legged Robots: System Design and Field Deployment
Abstract summary
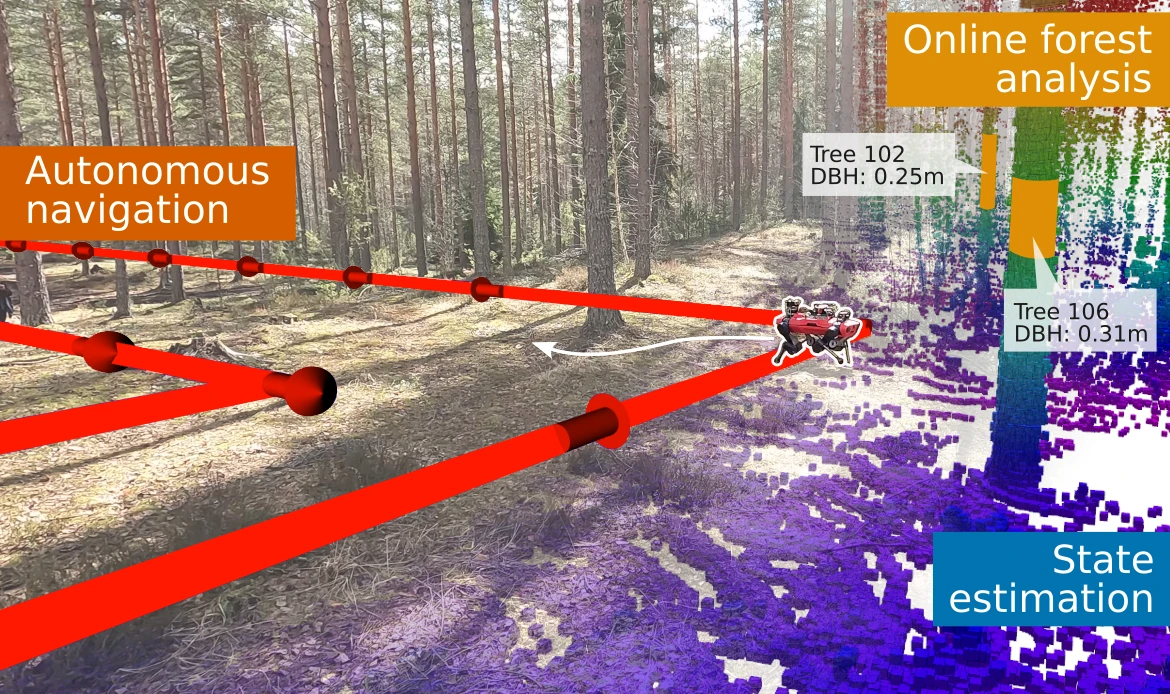
This workshop contribution presents an end-to-end system for forest inventory using a legged robot. State estimation, navigation and mission planning guide the robot through a survey area while online processing segments trees and estimates their properties. Legged locomotion offers a useful combination of mobility, endurance and limited soil disturbance in forest terrain. The paper reports preliminary results from three field campaigns in Finland and the United Kingdom and discusses practical lessons from deployment. In the Forest of Dean experiment, an ANYmal D surveyed 0.96 hectares autonomously in 20 minutes, identified more than 100 trees and achieved typical trunk-diameter accuracy of about two centimeters. These results describe an initial field demonstration of the integrated system.