GrandTour: A legged robotics dataset in the wild for multi-modal perception and state estimation
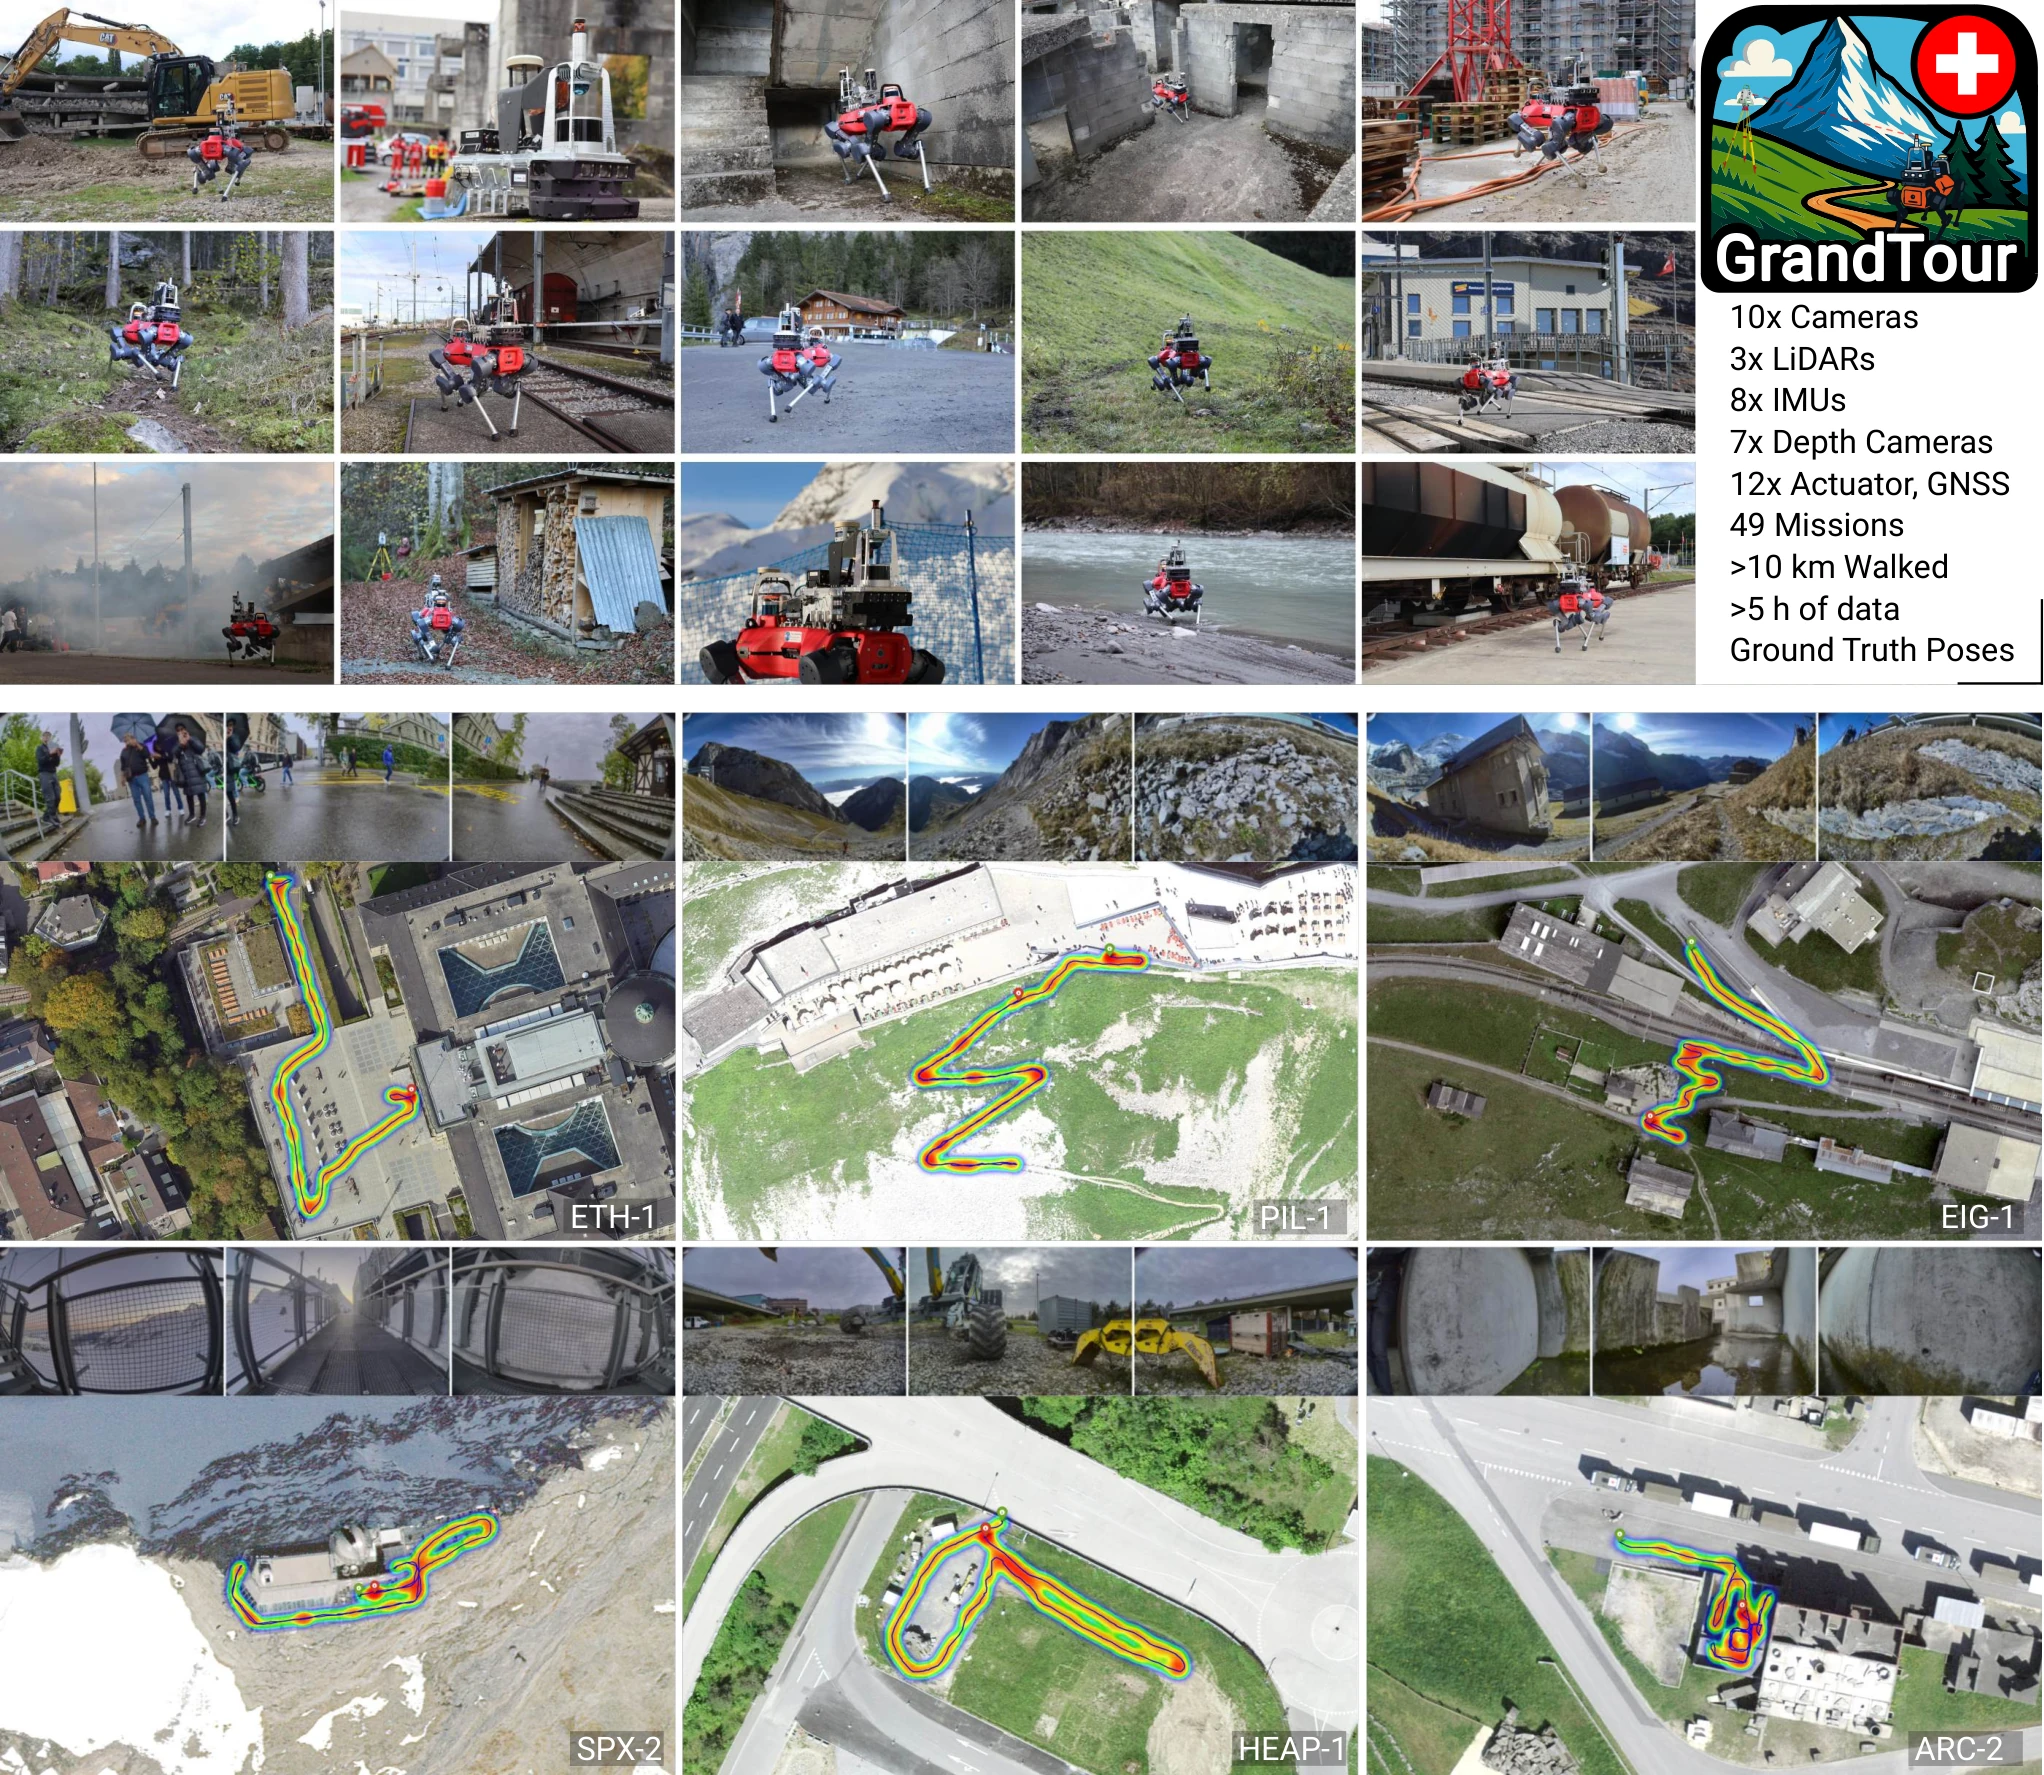
Abstract summary
GrandTour provides a shared basis for studying perception and state estimation on legged robots outside controlled laboratory settings. Data were collected with an ANYmal-D quadruped carrying the Boxi sensor payload in environments ranging from mountain paths and forests to urban spaces and damaged buildings. The recordings combine LiDAR, complementary RGB cameras, stereo and depth sensing, inertial measurements and robot proprioception. Carefully calibrated, synchronized measurements are accompanied by reference trajectories from RTK-GNSS and a surveying total station. The diversity of terrain, lighting, weather and motion supports evaluation of localization, mapping and multimodal learning under realistic deployment conditions. The dataset and supporting tools make these experiments reproducible across different approaches to legged-robot autonomy.