Holistic Fusion: Task- and Setup-Agnostic Robot Localization and State Estimation With Factor Graphs
Abstract summary
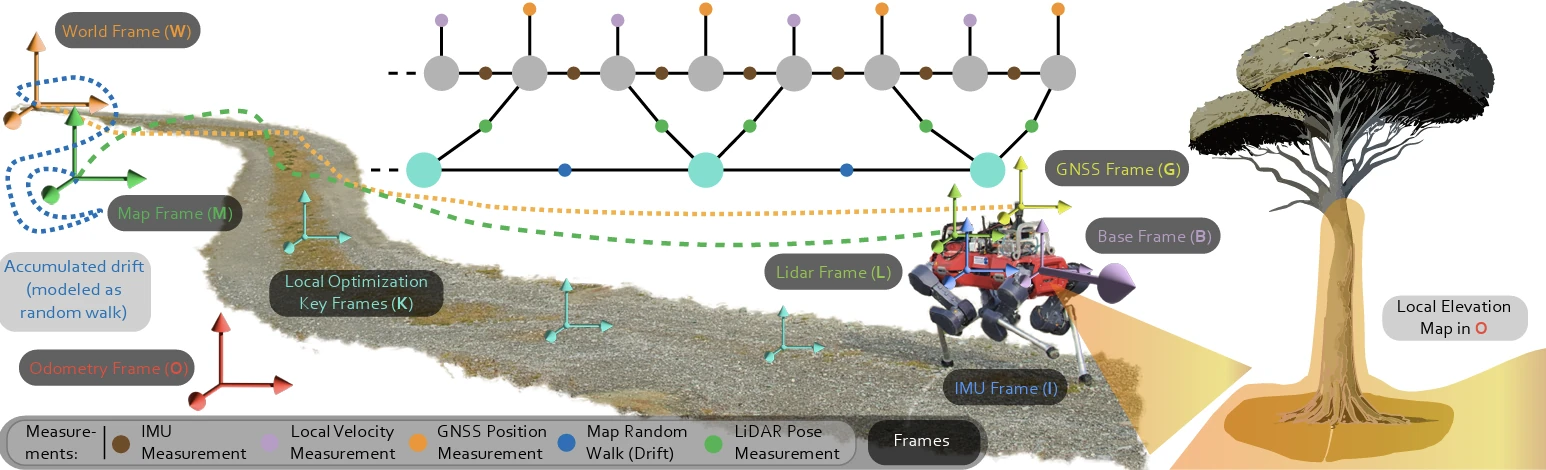
Holistic Fusion provides a common state-estimation framework for robots with different sensors and operating requirements. Rather than assuming that every measurement already shares a fixed reference frame, it estimates the robot state together with the relationships between measurement frames. Absolute observations, local motion estimates and landmarks can therefore enter the same factor graph. Time-varying frame alignment is modeled within the optimization, while the estimator maintains locally smooth motion estimates for control and mapping. An asynchronous smoothing process and IMU-rate propagation support online use on robot computers. Evaluation across five real-world scenarios and three platforms demonstrates how the framework accommodates different sensor combinations while maintaining accurate global localization and continuous local motion estimates.