Informed, Constrained, Aligned: A Field Analysis on Degeneracy-Aware Point Cloud Registration in the Wild
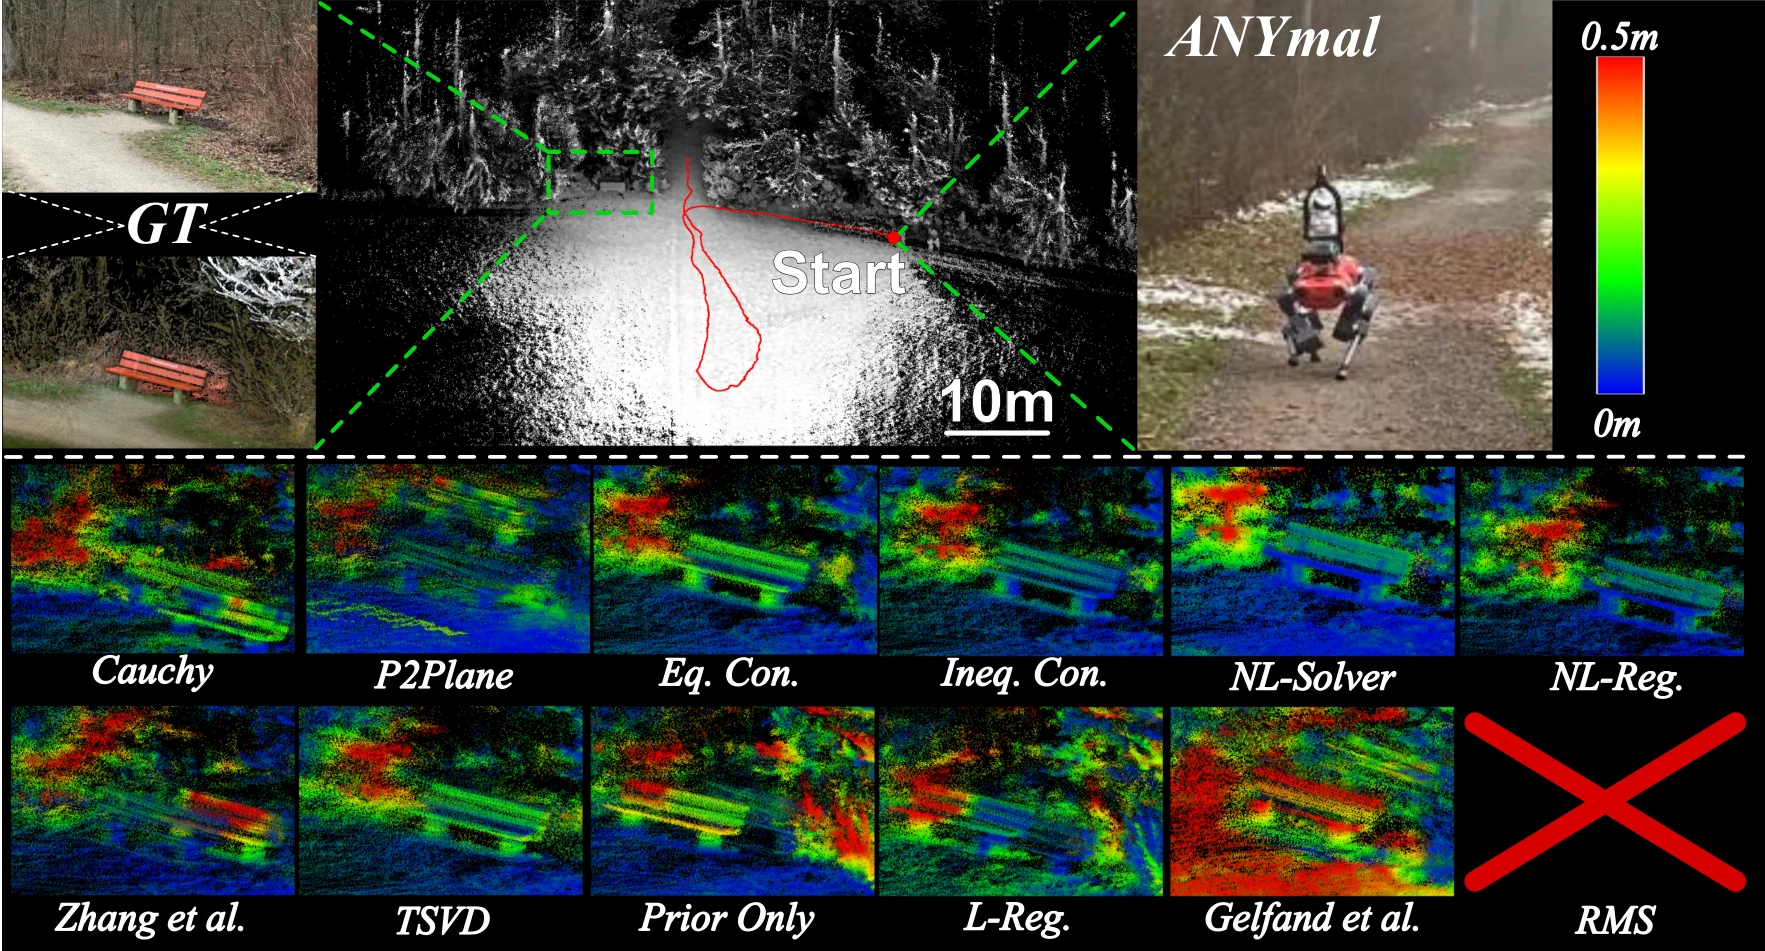
Abstract summary
This study examines what happens when ICP registration encounters geometry that cannot constrain every component of robot motion. It compares methods that detect degeneracy, modify the optimization or rely on additional pose information. The analysis includes truncated singular-value decomposition, equality and inequality constraints, and linear and nonlinear regularization. A sensitivity study connects these choices to their effect on the underlying least-squares problem. Simulations and deployments in forests, tunnels and restricted passages then test their practical behavior. The results show the value of actively handling degeneracy inside the optimization when reliable external estimates are unavailable. They also show that soft constraints can perform well in difficult scenes, while their tuning remains consequential. Code and evaluation data accompany the paper.