LEVA: A High-Mobility Logistic Vehicle with Legged Suspension
Abstract summary
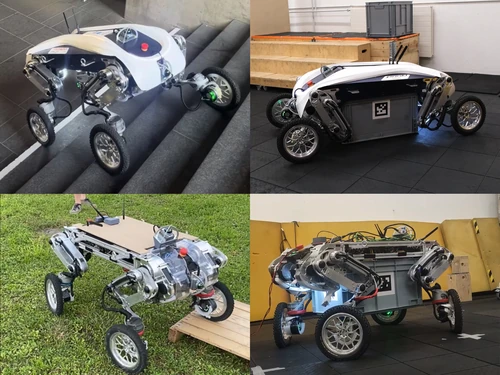
LEVA is designed to move materials through environments that are difficult for conventional wheeled logistics platforms. Its parallel-kinematic legged suspension combines the efficiency of rolling with the ability to adapt wheel positions to steps, inclines and uneven ground. A reinforcement-learning controller supports stair traversal, while a dedicated pickup mechanism enables autonomous loading of cargo boxes. The platform carries payloads of up to 85 kilograms and achieves a reported cost of transportation as low as 0.15 in the evaluated conditions. Experiments demonstrate loading, off-road driving and stair climbing. Together, these capabilities target logistics tasks in settings such as agriculture, construction and emergency response.