Global Path Planning for Autonomous Vehicles in Orchards and Vineyards
Abstract summary
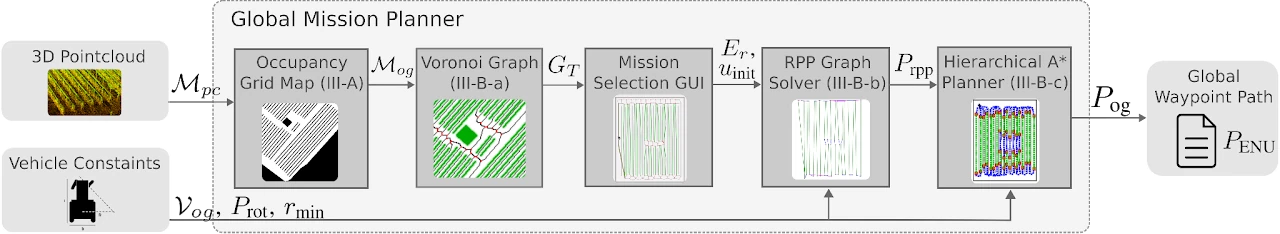
Agricultural coverage requires a vehicle to visit selected rows while negotiating obstacles and limited turning space. This work builds a global planning framework that accounts for both the structure of a field and the vehicle's kinematic constraints. A volumetric map is converted into a navigation graph, and the required coverage is expressed as a graph-routing problem. A hierarchical A* stage then turns the high-level route into feasible paths while working within a user-specified computation budget. Experiments use simulated and real-world environments with different vehicle configurations to examine route quality and feasibility. Further evaluations in a forest and a search-and-rescue training site demonstrate that the approach can extend beyond agricultural rows.