Continuous-Time State Estimation Methods in Robotics: A Survey
Abstract summary
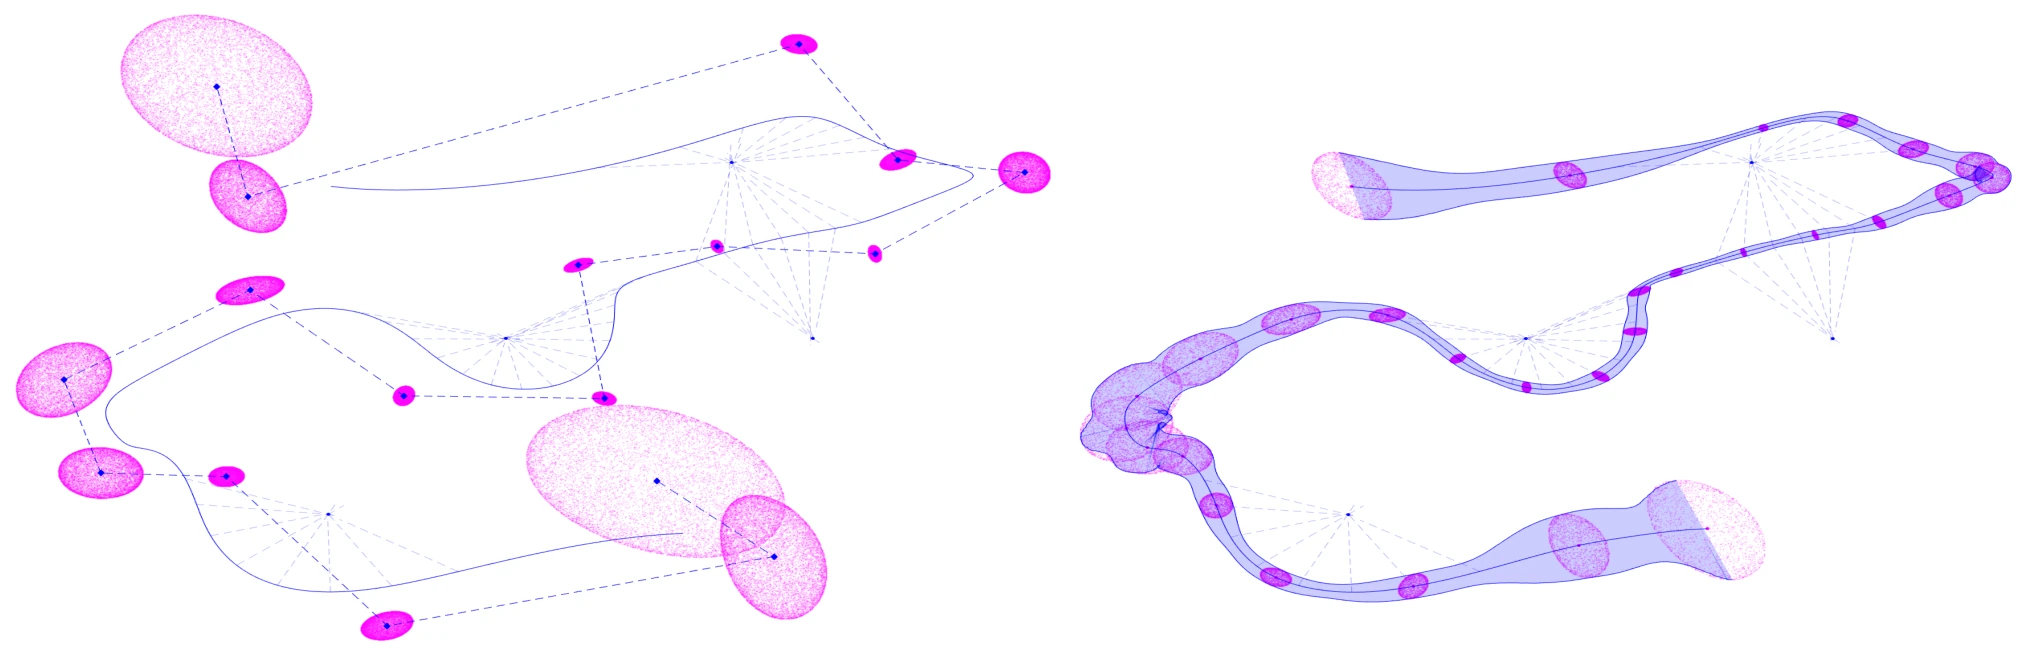
Continuous-time estimation represents a robot's state as a function that can be evaluated between sensor timestamps, rather than only at a sequence of discrete states. This can simplify the handling of asynchronous measurements and support motion estimation, planning and control at arbitrary query times. The survey develops a common perspective on approaches based on splines and Gaussian processes. It organizes prior work by mathematical method, estimated quantities, application and historical development, including relevant connections to other research fields. By examining both families together, it clarifies their relationships and practical tradeoffs. The review also identifies unresolved questions and promising directions for broader use of continuous-time methods in robotics.