TRaIL-Odom: Tightly Coupled Continuous Time Radar-IMU-LiDAR Odometry With Adaptive Doppler Weighting
Abstract summary
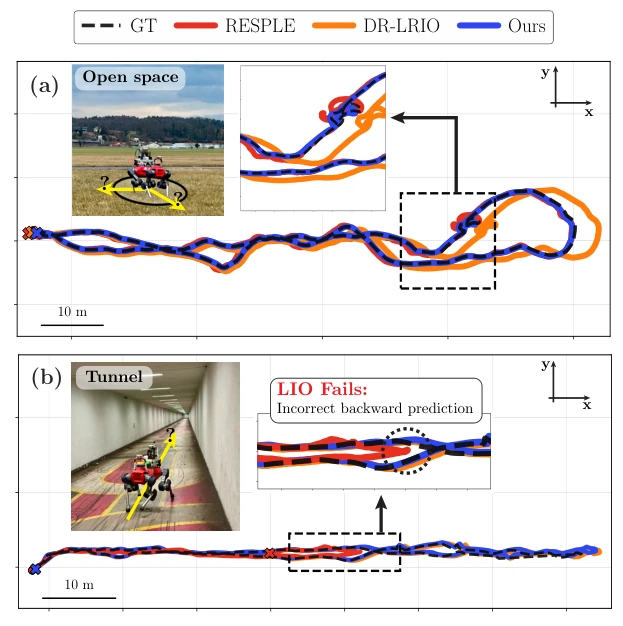
TRaIL-Odom combines radar, inertial and LiDAR measurements in a continuous-time estimator while adapting the contribution of radar to the available geometric information. It first identifies translational directions that LiDAR constrains poorly. Individual Doppler measurements are then weighted according to how much information they provide along those directions. A second mechanism changes the overall radar influence as the geometry becomes more or less informative. This avoids assigning the same importance to radar in every scene and direction. Evaluation covers 13 sequences, including open areas and tunnels. On three degenerate sequences, the combined weighting mechanisms reduce absolute and relative trajectory errors by 86.0% and 78.5%, respectively, compared with the fixed-weight baseline.